This was a tiny project to mimic something a project I did in college in a Robotics class. We used inverse kinematics to derive the required matrices and then the forces needed to move a robotic arm. This is a much simpler implementation in 2D. Stuff like this can be used for procedural animations (applying IK to rigging bones) and a ton of other things to create very realistic motion.
2D Inverse Kinematics
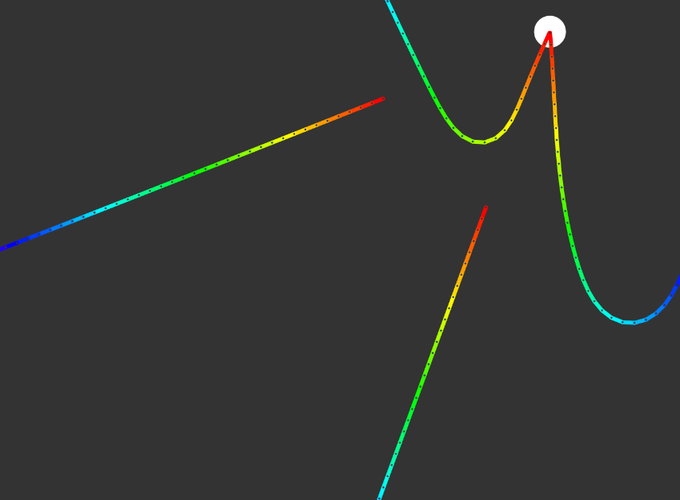
2D Inverse Kinematics
Amrit Amar
Senior AI Platform Engineer · Founder of Mopane Technologies
My research interests include artificial intelligence (particularly alignment, interpretability), data design and engineering, graphics, virtual/augmented reality, and quantum computing.